BotBrain Open Source
Free
Open hardware and software. Hardware and professional services are separate.
One stack for autonomy.
Navigation, missions, teleoperation, fleet control and custom AI models for humanoids, quadrupeds and any ROS 2 robot, free and open source. Clone the repository, print the enclosure, install it on a Jetson: about 30 minutes to a running robot.
- 01CloneThe ROS 2 packages, the web dashboard and the hardware files in one MIT-licensed repository.
- 02PrintThe two-tone enclosure and the mounts for your robot, as STL, STEP and 3MF.
- 03InstallOne script on a Jetson with JetPack 6.2, then open the web UI. About 30 minutes.
- ROS 2 robots it can run on
- 200+
- From clone to a running robot
- 30 min
- License
- MIT
What you get out of the box.
Dashboard and fleet control
Status, robot info and quick navigation across every connected robot.
CockPit
Front and rear cameras, 3D model, map, navigation and quick controls on one screen.
My UI
A customizable control interface built from the CockPit widgets.
Missions
Create and run autonomous navigation missions.
Health
CPU, GPU and RAM usage, state-machine control and Wi-Fi management.
RTABMap SLAM and Nav2
Visual SLAM, mapping and autonomous navigation.
ROSA natural-language control
LLM-based commands for the robot.
Safety controls
Dead-man switch, emergency stop and priority-based velocity arbitration.
YOLO object detection
Coming soonYOLOv8 / v11 detection and detection history.
Everything you need to print, mount and run.
01 / Printable two-tone enclosure
STL, STEP and 3MF files for the shell and the robot mounts.
02 / NVIDIA Jetson Orin Nano
Reference assembly; Jetson Nano also supported.
03 / 2× Intel RealSense D435i
Front and rear depth cameras for mapping and navigation.
04 / Go2 · G1 · Direct Drive Tita mounts
Open mounting interfaces for the supported robots.
BotBrain Open Source
The software, up close.
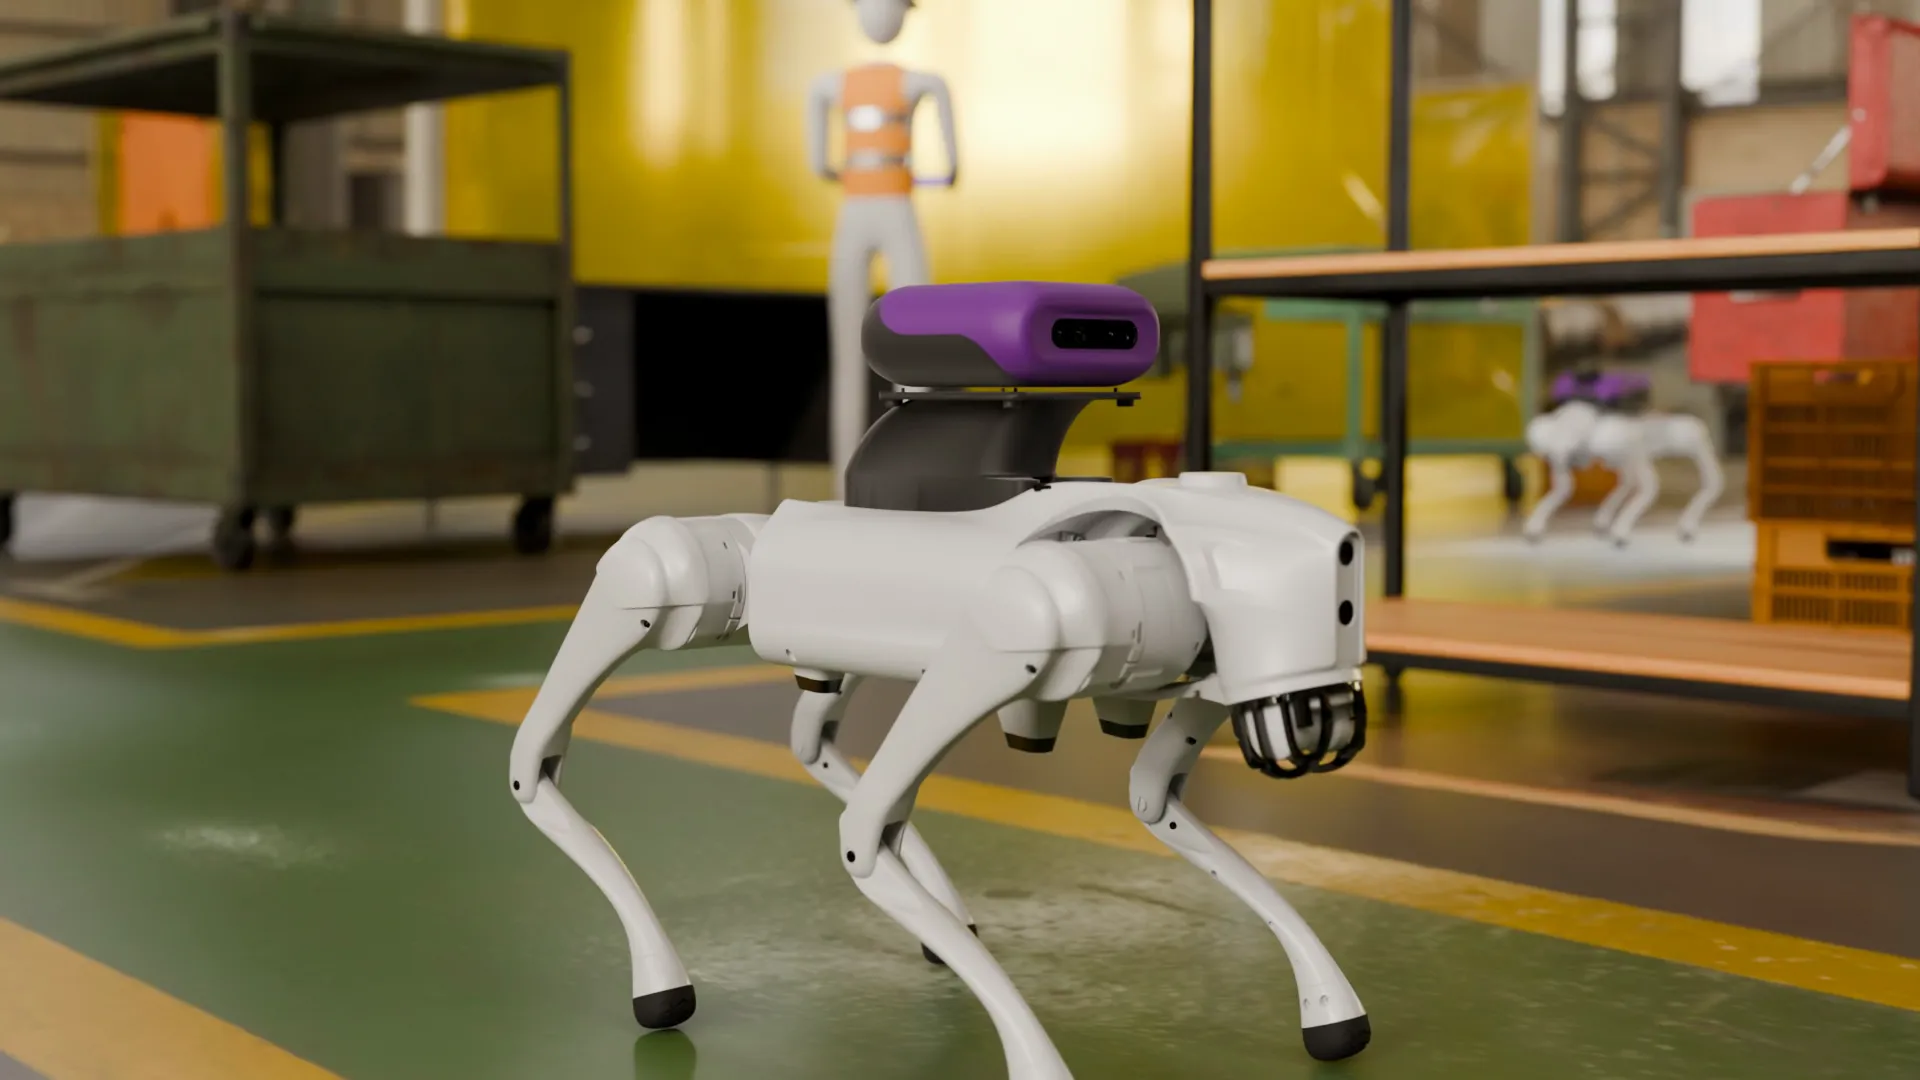
CockPit, My UI, Flows, Maps and the AI agent, recorded live on a Go2 in our lab.

Running in about 30 minutes.
On a Jetson with JetPack 6.2 (Ubuntu 22.04), Docker and a free Supabase project.
$ git clone https://github.com/botbotrobotics/BotBrain.git$ cd BotBrain$ sudo ./install.sh$ sudo reboot# Then open the web UI at http://<jetson-ip>.How the project is organized.
- ├── frontend/Next.js web dashboard (React, TypeScript, Supabase auth).
- ├── botbrain_ws/src/13 ROS 2 Humble packages: bringup, interfaces, description, localization, navigation, ROSA, state machine, YOLO, joystick, Jetson stats and the go2, g1 and tita robot packages.
- ├── hardware/Printable enclosure and robot mounts as STL, STEP and 3MF, with the assembly guide.
- └── docs/Installation, Supabase setup, G1 Wi-Fi setup, dependencies and the MIT license.
Six robots with ready drivers, and any other ROS 2 robot.
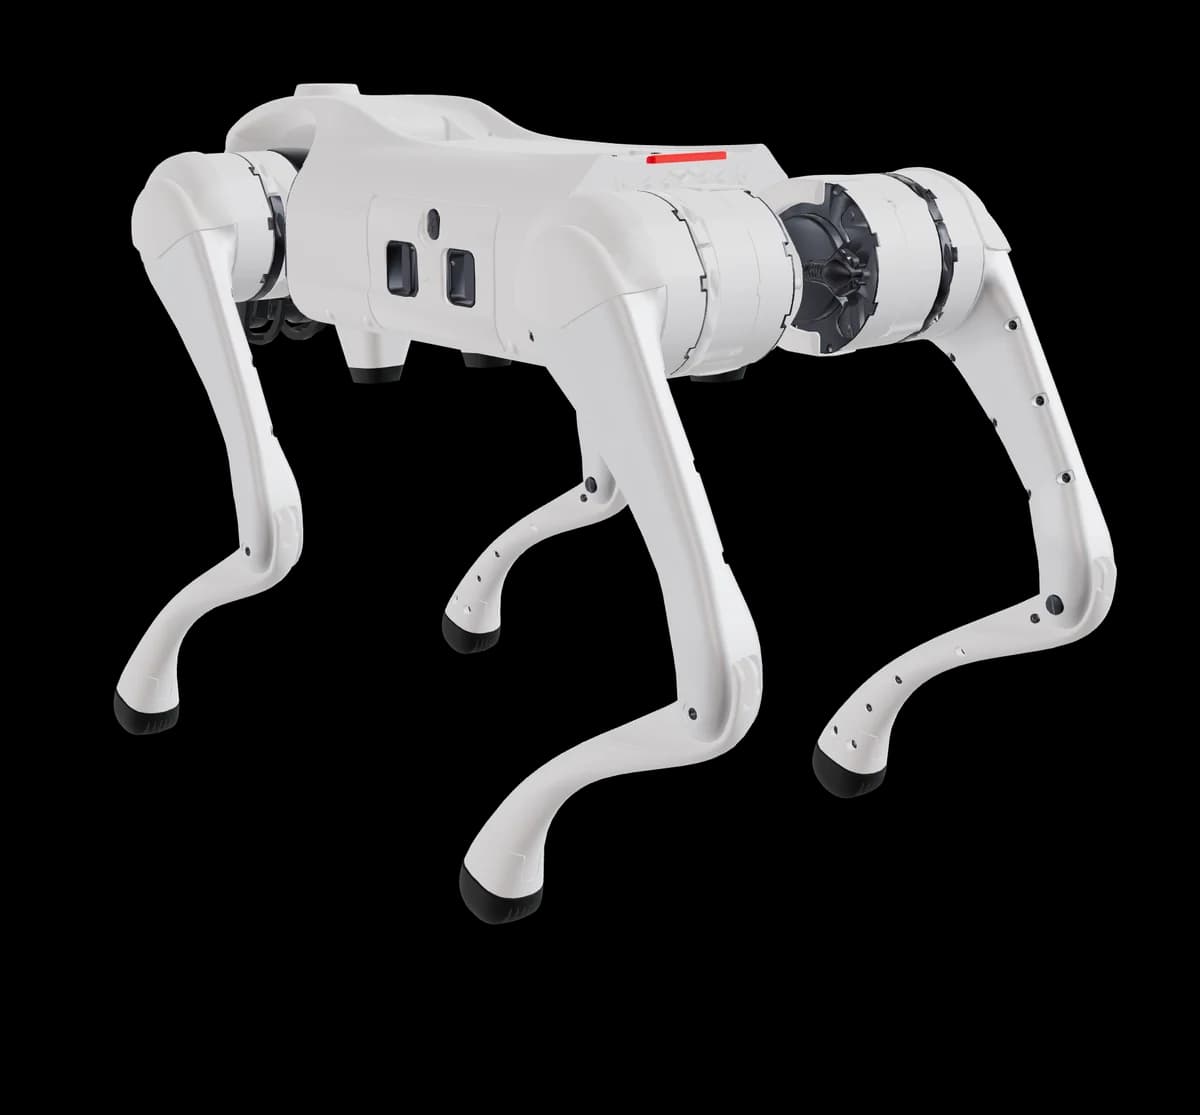
Go2, Go2-W, G1, G1-D, Direct Drive Tita and Booster K1 come with driver packages. Any other ROS 2 robot, legged or wheeled, joins with a driver package and a robot config, and more than 200 platforms ship with ROS 2 today.
- Unitree Go2 / Go2-W
- Unitree G1 / G1-D
- Direct Drive Tita

- Booster K1
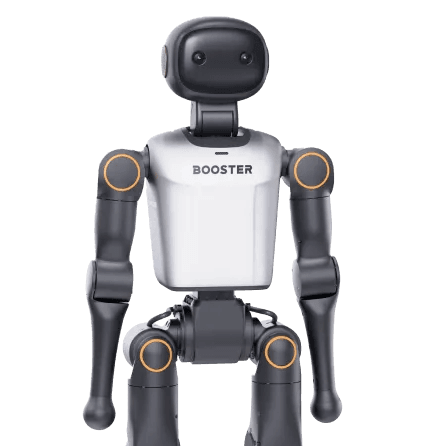
- Bring your own robotAny ROS 2 robot, legged or wheeled. Add a driver package and a robot config; the rest of the stack stays the same.How to add a robot


BotBrain Open Source specifications
- Compute
- NVIDIA Jetson
- Jetson Nano and Orin Nano supportOrin Nano in the reference assemblySelect modules for the available compute
- Vision & network
- 2× RealSense D435i
- Front and rear camera supportVisual and depth data for mappingEthernet or Wi-Fi connection
- Robotics software
- ROS 2 Humble
- RTABMap for visual SLAMNav2 for autonomous navigationWaypoint missions and map management
- Orin Nano environment
- JetPack 6.2
- Ubuntu 22.04 recommendedDocker and Docker ComposeContainerized robot and web services
- Web application
- Browser-based control
- Next.js 15, React 19 and TypeScriptFleet dashboard, cockpit and diagnosticsSupabase for authentication and data
- Open hardware
- Build and adapt
- Printable enclosure and robot mountsSTL, STEP and 3MF filesGo2, G1 and Direct Drive Tita mounting interfaces
GitHub reference, September 2026. AGX / Thor board support and selected perception features are listed as coming soon.
Open Source or Pro: choose your path.
Compare the software, hardware and support included in each approach.
| BotBrain Open Source | BotBrain Pro | |
|---|---|---|
| Robot operations | Teleoperation, navigation, missions and fleet control | All Open Source core capabilities |
| Apps & interfaces | Web browser | Web, iOS, Android, Windows and macOS |
| Edge compute | Jetson Nano / Orin Nano · open reference build | Jetson AGX Orin 64 GB · up to 275 TOPS |
| Connectivity | Ethernet and Wi-Fi · configured by your team | Ethernet, 3G / 4G / 5G, Wi-Fi 6, HaLow and Bluetooth |
| Depth cameras | 2× RealSense D435i · reference assembly | 2× RealSense D455 |
| Enclosure | Printable enclosure and robot mounts · open hardware files | Full polycarbonate · BotBrain payload interface |
| Custom AI & integrations | Open code to extend with your team | Pro SDK, custom AI models, payloads and application integrations |
| Deployment & support | Your engineering team and community resources | BotBot setup, maintenance and dedicated support |
| Pricing model | Free software and hardware designs · hardware purchased separately | Pilot program today · general production February 2027 |
Robot operations
- BotBrain Open Source
- Teleoperation, navigation, missions and fleet control
- BotBrain Pro
- All Open Source core capabilities
Apps & interfaces
- BotBrain Open Source
- Web browser
- BotBrain Pro
- Web, iOS, Android, Windows and macOS
Edge compute
- BotBrain Open Source
- Jetson Nano / Orin Nano · open reference build
- BotBrain Pro
- Jetson AGX Orin 64 GB · up to 275 TOPS
Connectivity
- BotBrain Open Source
- Ethernet and Wi-Fi · configured by your team
- BotBrain Pro
- Ethernet, 3G / 4G / 5G, Wi-Fi 6, HaLow and Bluetooth
Depth cameras
- BotBrain Open Source
- 2× RealSense D435i · reference assembly
- BotBrain Pro
- 2× RealSense D455
Enclosure
- BotBrain Open Source
- Printable enclosure and robot mounts · open hardware files
- BotBrain Pro
- Full polycarbonate · BotBrain payload interface
Custom AI & integrations
- BotBrain Open Source
- Open code to extend with your team
- BotBrain Pro
- Pro SDK, custom AI models, payloads and application integrations
Deployment & support
- BotBrain Open Source
- Your engineering team and community resources
- BotBrain Pro
- BotBot setup, maintenance and dedicated support
Pricing model
- BotBrain Open Source
- Free software and hardware designs · hardware purchased separately
- BotBrain Pro
- Pilot program today · general production February 2027
Hardware, robot support and service scope are confirmed per deployment. Open Source hardware is not included in the free software offer.
Every feature, side by side.
Software, apps and services in BotBrain Open Source and BotBrain Pro.
| Feature | Open Source | Pro |
|---|---|---|
| Software | ||
| ROS 2 robot supportSupported robots and custom ROS 2 platforms | ||
| Live camera, sensor and LiDAR viewStream cameras, sensors and LiDAR data in real time | ||
| Real-time custom dashboardBuild control interfaces for operators | ||
| Autonomous navigation and missionsSet waypoints and let the robot navigate | ||
| Keyboard, joystick and gamepad controlsKeyboard, on-screen joystick or game controllers | ||
| Fleet controlMonitor and command several robots from one dashboard | ||
| On-screen video overlaysCrosshairs, grids and custom overlays on video feeds | ||
| Mission builderPlan missions with variables and actions | ||
| Simple AI integration (YOLO)Object detection with YOLO models | ||
| Block programmingAutonomous behaviours with visual programming | ||
| AI chat agentNatural-language robot commands | ||
| User profiles and authenticationAccounts and access permissions | ||
| Map builder and editorCreate and edit navigation maps | ||
| System and robot health monitorTrack system and robot health in real time | ||
| 3G to 5G connectivityCellular networks for remote operations | ||
| GPS RTKCentimetre-level positioning for navigation | ||
| Global data relayConnect to and control robots from anywhere | ||
| Custom AI modelsVision, world and language models for your application | ||
| Text-to-speechSpoken announcements from the robot | ||
| SoundboardUpload and play custom sounds | ||
Build it with us.
Questions, builds and pull requests happen on GitHub and Discord. Fork the repository, add tests, keep the READMEs current and open a pull request.